Heat Sensor Camera Guide: Working Principles, Resolution, and OEM Selection
Heat Sensor Camera Guide: Working Principles, Resolution, and OEM Selection
Modern infrared imaging has broken out of the era of basic handheld industrial thermometry. Today, it is driving high-speed embedded computer vision, autonomous drone navigation, and round-the-clock perimeter security. At the mechanical and electrical core of the uncooled LWIR heat sensor camera modules covered here is a straightforward job: translate infrared radiation into spatial image data; calibrated temperature measurement requires a radiometric configuration.
For system architects, electro-optical engineers, and OEM payload designers, integrating a thermal core means wrestling with microbolometer pixel pitch, thermal sensitivity (Noise Equivalent Temperature Difference, or NETD), optics selection via the Johnson criteria, and high-throughput digital interfaces. When SWaP-C (Size, Weight, Power, and Cost) budgets get squeezed tight across robotics, defense, industrial automation, and aerial platforms, picking an appropriate uncooled focal plane array with a matching compute pipeline makes or breaks your build.
Look, thermal core engineering requires an honest understanding of detector semiconductor physics, optical throughput (f-number matching), shutterless versus mechanical Non-Uniformity Correction (NUC), and digital streaming latency. In the shop, whether you are cobbling together a dual-spectrum tracking gimbal for an unmanned aerial vehicle (UAV) or bolting down fixed uncooled microbolometers for continuous predictive maintenance, you have to weigh physical detector dynamics against real-time edge AI inferencing loads. This technical guide breaks down the underlying physics of long-wave infrared (LWIR) sensing, evaluates resolution trade-offs from entry-level formats up to high-density 640×512 arrays, walks through optical DRI calculations, and reviews OEM integration protocols for embedded hardware development cycles.
Table of Contents
- 👉 1. Working Principles & Sensor Physics of Heat Sensor Cameras
- 👉 2. Resolution Tiers, IFOV, and Optical DRI Calculations
- 👉 3. Dual-Spectrum Fusion, Low-Latency Video, and Edge AI Architectures
- 👉 4. OEM Product Showcases: High-Performance Cores & AI Platforms
- 👉 5. Comparative Technical Benchmark
- 👉 6. Electrical, Interface, and Thermal Dissipation Integration
- 👉 7. Deep-Dive Technical FAQ
- 👉 8. Engineering Consultation & Next Steps
1. Working Principles & Sensor Physics of Heat Sensor Cameras
The uncooled heat sensor cameras covered here detect electromagnetic radiation in the thermal infrared band, typically in the Long-Wave Infrared (LWIR) band around 8 µm to 14 µm. Visible-light CMOS and CCD imagers detect visible photons, commonly from reflected illumination or luminous objects. Thermal cameras respond to infrared radiation reaching the detector, including surface emission and reflected surroundings. Planck’s Radiation Law describes the emitted spectrum, while Wien’s Displacement Law describes its wavelength peak. Total hemispherical radiant emittance over all wavelengths follows the Stefan-Boltzmann relation, with total emissivity included for a non-blackbody surface:
W = ε σ T4
In this equation, W is radiant emittance (W/m²), ε is total surface emissivity (0 for an ideal reflector and 1 for a blackbody), σ is the Stefan-Boltzmann constant (approximately 5.67 × 10⁻⁸ W·m-2·K-4), and T is absolute temperature in kelvin. Here’s the deal: a 300 K blackbody has a wavelength-spectrum peak near 9.7 µm. That places LWIR in a useful band for passive terrestrial sensing in darkness. Fog, rain, smoke, reflections, and target contrast can still limit image quality and range.
Microbolometer Material Physics: Vanadium Oxide (VOx) vs. Amorphous Silicon (a-Si)
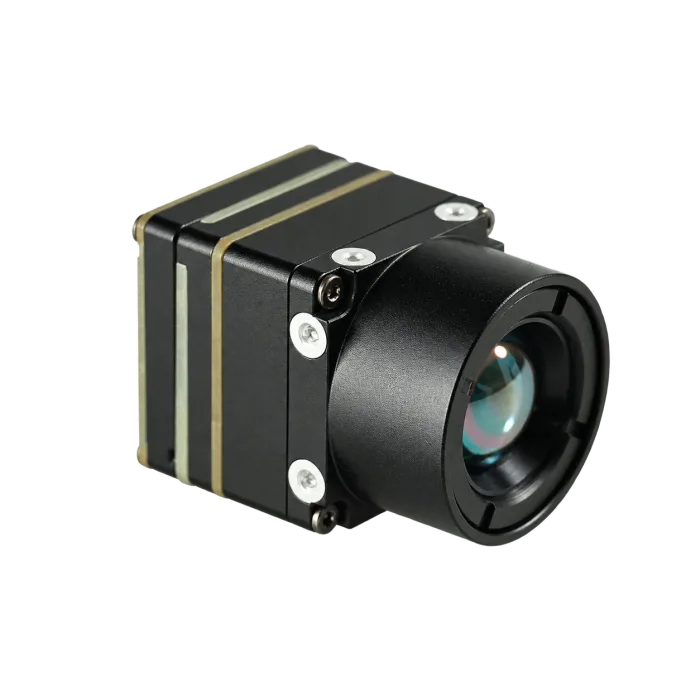
Inside an uncooled thermal core sits the microbolometer Focal Plane Array (FPA). Every individual pixel across the matrix consists of a tiny infrared-absorbing micro-membrane suspended over an underlying silicon Readout Integrated Circuit (ROIC). This membrane sits on micro-machined bridge legs that limit heat conduction to the substrate; the detector package maintains the vacuum. As incoming LWIR photons hit the membrane, its temperature shifts, changing its internal electrical resistance. How well that transducer behaves depends on the sensing film, pixel structure, readout, and operating conditions:
- ⚙️ Vanadium Oxide (VOx): VOx is a widely used microbolometer sensing material. Published thin-film studies report negative Temperature Coefficients of Resistance (TCR) around -2% to -3% per kelvin near room temperature, depending on composition and processing. Detector noise, thermal response, and NETD also depend on the pixel and readout design; a ≤30 mK rating cannot be inferred from VOx chemistry alone.
- ⚙️ Amorphous Silicon (a-Si): Amorphous silicon (a-Si) benefits from mature silicon fabrication processes. Its TCR, noise, and thermal time constant depend on the film and pixel design. Thin a-Si membranes can support short response times, so a-Si should not be assigned an inherently slower response or a fixed 40 mK to 50 mK noise floor. Compare measured detector specifications under matched conditions.
Noise Equivalent Temperature Difference (NETD) and Optoelectronic Sensitivity
Noise Equivalent Temperature Difference (NETD) is a key metric for thermal sensitivity. Expressed in millikelvins (mK), it is the scene-temperature difference that produces a signal equal to the RMS noise (SNR = 1) under stated measurement conditions. A useful measurement definition is:
NETD = Vn,rms / |dV/dTscene|
Here, Vn,rms is RMS output noise and dV/dTscene is the output response per unit scene-temperature change, measured at the same output stage and settings. Compare NETD at matched lens f-number, scene temperature, frame rate, and processing conditions. Lower NETD helps resolve weaker thermal contrast, but a 30 mK specification does not guarantee a particular scene or weather performance, and NETD is not temperature-measurement accuracy.
Non-Uniformity Correction (NUC) and Thermal Drift Dynamics
Because microbolometer pixels have tiny manufacturing variations in nominal resistance, thermal mass, and TCR, raw readouts show noticeable spatial Fixed Pattern Noise (FPN). To make matters trickier, temperature changes inside the camera housing alter the internal background radiation bleeding off the lens barrel and internal chassis onto the array. Embedded thermal engines clean this up using two primary methods:
- 📌 1. Mechanical Shutter NUC: A mechanical shutter presents a uniform reference to the FPA so the processor can update pixel offset corrections. It adds a moving part and may briefly freeze or interrupt live video. Interruption duration depends on the core and settings; verify it in the intended operating mode.
- 📌 2. Shutterless Algorithmic NUC: Shutterless implementations may use scene statistics, temperature compensation, or both to reduce non-uniformity without an internal shutter event. Performance depends on the core, scene, motion, and temperature changes; some designs still need an external uniform reference. Validate residual artifacts and continuity for robotic vision and inspection.
2. Resolution Tiers, IFOV, and Optical DRI Calculations
Choosing your sensor resolution affects image detail and downstream data and computation loads. Entry-level monitoring architectures can prioritize compact, lower-resolution cores when cost and power budgets are tight. More demanding inspection, search-and-rescue, and monitoring tasks may benefit from a larger array, but target size, optics, contrast, and operating conditions still determine the useful detail.
Stepping up from a 160×120 array (19,200 total pixels) or a 256×192 array (49,152 total pixels) to a 640×512 array (327,680 total pixels) provides 6.67× as many pixels as a 256×192 sensor. As detailed in our breakdown on choosing 640×512 thermal camera modules for drone payloads, the benefit depends on the optics. At matched angular coverage, a larger array can sample the scene more finely; at the same pixel pitch and focal length, IFOV stays the same and the larger array covers a wider field. Optical blur, noise, and image processing also affect resolved detail.
Instantaneous Field of View (IFOV) and Optical Calculations
Instantaneous Field of View (IFOV) describes the angular sampling interval of a pixel. Near the optical axis, the small-angle estimate is pixel pitch divided by focal length. Actual resolved detail also depends on optical blur, focus, noise, and processing:
IFOV (mrad) ≈ Pixel Pitch (p in µm) / Focal Length (f in mm)
For a generic example, take a sensor with a 12 µm pixel pitch and a 9.1 mm focal length lens:
IFOV ≈ 12 / 9.1 mrad = 1.31868… mrad ≈ 1.319 mrad
To estimate the projected size of one pixel near the optical axis at distance (R), multiply the range by IFOV in radians:
Single-Pixel Footprint ≈ Distance (R) × IFOV (radians)
At 200 meters, this example gives a single-pixel footprint of approximately 200 m × 0.00131868 = 0.2637 meters (26.37 cm). This is a sampling footprint, not a guaranteed temperature-measurement spot. For radiometric measurement, a target covering at least 3×3 pixels is a common starting rule; follow the camera’s specified measurement field of view, focus, and target-fill requirements.
Johnson’s Criteria for DRI (Detection, Recognition, Identification)
Monitoring and search-and-rescue systems often use Johnson-style DRI models for initial optical comparisons. State the chosen target dimension, probability, and model convention: pixel thresholds are not interchangeable with line-pair thresholds. One commonly published FLIR convention uses 1.5, 6, and 12 pixels across the target’s critical dimension. These estimates do not guarantee field performance or AI classification accuracy:
- 🔍 Detection (1.5 pixels in this convention): An observer judges that an object is present under the model’s assumptions.
- 🔍 Recognition (6 pixels in this convention): An observer distinguishes a broad object class, such as a person, animal, or vehicle.
- 🔍 Identification (12 pixels in this convention): An observer distinguishes finer attributes or similar objects under the model’s assumptions.
When speccing out lenses for a thermal camera, longer focal lengths narrow the Field of View (HFOV/VFOV) on a given sensor and place more pixels across distant objects. Shorter focal lengths cover a wider scene for nearby inspection and navigation. Validate the final system with representative targets, contrast, weather, focus, and motion; focal length alone does not establish a detection range.
3. Dual-Spectrum Fusion, Low-Latency Video, and Edge AI Architectures
Modern thermal setups have moved far beyond isolated analog video feeds. Some aerospace, security, and robotic systems use dual-spectrum payloads that pair visible electro-optical (EO) cameras directly with long-wave infrared (LWIR) cores, linking both to an onboard Neural Processing Unit (NPU) for real-time edge AI tracking.
Multi-Spectral Pixel Fusion Methodologies
Visible CMOS sensors provide edge definition, textures, and readable signage when illumination and contrast are sufficient. Passive LWIR imaging works without visible illumination and may retain useful contrast in some smoke or light-fog conditions, but it does not reveal visible surface color or guarantee a view through obscurants. Dual-spectrum processors can present the complementary streams in several ways:
- ⚙️ Picture-in-Picture (PIP): A scaled thermal view is placed within a visible view, or vice versa, so operators can compare thermal hotspots with the wider scene. Output resolution and alignment depend on the implementation.
- ⚙️ High-Frequency Edge Blending (Spatial Fusion): An edge-overlay algorithm can extract visible outlines and add them to the thermal display. Accurate registration is needed for useful alignment, especially with different fields of view, parallax, or timing. The filter, bit depth, and preservation of radiometric data depend on the implementation.
- ⚙️ Dynamic Range Compression (DRC) & Palette Mapping: Histogram-based or local tone mapping can make details easier to see when hot and cool objects share a scene. These display operations do not recover information lost to detector saturation or establish temperature accuracy.
Edge AI Inference and Tracking Engines
Running computer vision models directly at the edge can reduce dependence on transmitting raw video to a remote processor; end-to-end latency still includes acquisition, processing, buffering, and output. For machine-vision hardware using CoaXPress, the JIIA CoaXPress Certification Program provides product-compliance procedures and testing. Compact embedded systems may instead use MIPI CSI-2 or USB UVC. Confirm the camera, host, driver, and required output format together.
Dedicated NPU hardware can accelerate supported object-detection models on an embedded platform. A 4 to 6 TOPS rating alone does not establish model compatibility, accuracy, frame rate, or tracking continuity. Benchmark the actual model, input resolution, runtime, memory traffic, synchronization, and full video pipeline under representative lighting and occlusion conditions.
4. OEM Product Showcases: High-Performance Cores & AI Platforms
To help you select the right hardware balance between compact SWaP-C profiles and edge-AI compute capabilities, let’s examine two current configurations for professional integration.
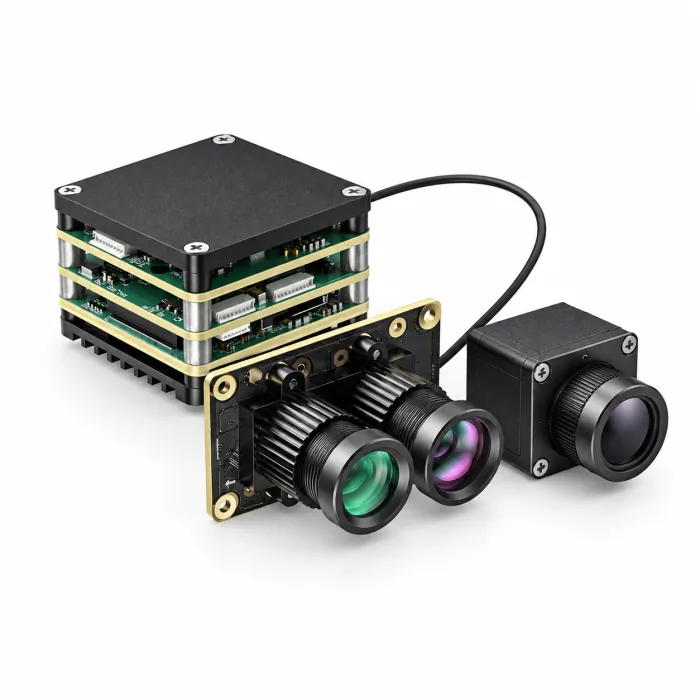
CAMCUDA AI VisionCube DT Pro with Dual Visible Cameras and 640×512 Thermal Imaging
Integrated Visible and Thermal Imaging for Civilian Inspection & Observation
The CAMCUDA AI VisionCube DT Pro combines two visible cameras, a 640×512 thermal camera and 6 TOPS AI processing for civilian inspection and observation. Its visible output is 1920×1080 at 30 Hz, with 3.9 mm wide-angle and 12 mm telephoto optics; the 12 µm thermal camera uses a 9.1 mm lens and runs at 50 Hz. Confirm the supplied software, tracking functions and host interfaces for your project before treating the package as a complete processing solution.
Comprehensive Technical Specifications:
| AI Processing, Tracking & Compute | |
|---|---|
| AI Compute Performance | 6 TOPS advertised AI processing; confirm the supported model and software |
| CPU Architecture | Not specified for DT Pro on the current listing; request the SoC and CPU specification |
| Simultaneous Target Tracks | No verified DT Pro track-count specification; confirm the model and firmware limit |
| Target Classification Types | Confirm the supported classes and validation data for the supplied AI model |
| Standoff Reference Tracking | No guaranteed DT Pro tracking distance; validate a sample in the intended scene |
| Minimum Resolvable Target | No published DT Pro minimum target-pixel threshold; confirm against the selected model |
| Dynamic Speed Reference | No verified DT Pro speed rating; supplier demonstration annotations are not specifications |
| Processing Latency | Not specified; measure capture-to-output latency with the supplied software and host |
| Supported Display / Tracking Modes | Picture-in-picture is documented; request the supported tracking modes and software |
| Electro-Optical (Dual Visible) Channels | |
| Optical Sensor Size | Brochure has 1/2.8-inch and 1/2.6-inch entries; confirm the final dual-visible sensor bill of materials |
| Visible Resolution & Rate | 1920 × 1080 visible output at 30 Hz |
| Focal Length & FOV | 3.9 mm wide: 72° H × 45° V; 12 mm telephoto: 26° H × 15° V |
| Visible Sensitivity Reference | 9650 mV/lux·s as supplied in the brochure; not a minimum-illumination lux rating |
| Visible Camera Dimensions | 40.8 × 25 × 26 mm dual-visible camera component; not the complete kit |
| Thermal (LWIR) Channel | |
| Detector Chemistry | Not specified in the current DT Pro listing; confirm the detector material |
| Array Resolution & Pitch | 640 × 512 active pixels | 12 µm pixel pitch |
| Spectral Response Band | 8–14 µm LWIR |
| Thermal Video Output | 50 Hz; USB is listed for the thermal camera component |
| Optics & Field of View | 9.1 mm thermal lens | 45.9° H × 36.9° V |
| Electrical, Control & Mechanical | |
| Input Supply Voltage | 9–16 V processing-board input; confirm wiring and the required supply margin |
| Telemetry / Control Protocols | Request the DT Pro protocol and SDK package; CRSF and autopilot compatibility are not verified |
| Compute Board Dimensions | 38 × 38 × 29 mm | 25.5 × 25.5 mm mounting | 43.8 g board only |
Integration Note: Picture-in-picture is documented for VisionCube, but the current DT Pro listing does not specify calibrated temperature range or accuracy. Do not assume radiometric thermography. Request the configuration-specific protocol, SDK, wiring guide, power budget and acceptance test data; the supplier demonstration does not establish guaranteed distances, speeds or track counts.
CAMCUDA AeroMini 640 640×512 Uncooled VOx Thermal Imaging Core
Compact Uncooled Thermal Imaging Core for Industrial & Robotic Payloads
The CAMCUDA AeroMini 640 combines a 640×512 uncooled VOx array with 12 µm pixels. The reference configuration here is non-radiometric, with a 9 mm lens and USB + CVBS + MIPI interface board: 60 Hz is the factory default, with 30 Hz available as a factory option. The specified NETD is ≤30 mK at 25 °C and F/1.0; typical module power is <0.7 W at 25 °C, and the <20 g mass excludes the lens and flange. This configuration shows thermal patterns for inspection and robotic payloads; it does not provide calibrated temperature readings.
Comprehensive Technical Specifications:
| Detector & Optical Parameters | |
|---|---|
| Detector Chemistry | Uncooled Vanadium Oxide (VOx) Focal Plane Array |
| Array Resolution | 640 × 512 active pixels |
| Pixel Pitch | 12 µm |
| Spectral Sensitivity | 8–14 µm LWIR |
| Thermal Sensitivity (NETD) | ≤30 mK at 25 °C, F/1.0; compare ratings under matching test conditions |
| Factory Frame Rate | 60 Hz default; 30 Hz factory option for non-radiometric imaging |
| Optical Aperture Rating | F/1.0 |
| Image Pipeline Latency | No verified end-to-end latency bound; test the selected output and host |
| Factory Lens Examples & Nominal IFOV | |
| 4 mm Lens Example | FOV: 100° × 82° | nominal IFOV: 3.000 mrad |
| 7 mm Lens Example | FOV: 64° × 52° | nominal IFOV: 1.714 mrad |
| 9 mm Selected Configuration | FOV: 48.7° × 38.6° | nominal IFOV: 1.333 mrad |
| 13 mm Lens Example | FOV: 31.9° × 25.7° | nominal IFOV: 0.923 mrad |
| 18 mm Lens Example | FOV: 24.2° × 19.5° | nominal IFOV: 0.667 mrad |
| 35 mm Lens Example | FOV: 12.5° × 10° | nominal IFOV: 0.343 mrad |
| Electrical, Video Interface & Environmental | |
| Interface Output Configuration | Selected USB + CVBS + MIPI board; confirm formats, frame rates and host compatibility |
| Power Consumption | <0.5 W typical module power at 25 °C; complete-kit power may differ |
| Operating Supply Input | Illustrated POWER_IN1 / POWER_IN2 inputs are 5 V; the family 12 V entry does not apply to these pins |
| Operating Temperature Range | −40 °C to +80 °C; an operating range, not a temperature-measurement range |
| Core Module Weight | <20 g excluding lens and flange; confirm the complete selected assembly mass |
Factory Lens Note: The table shows selected AeroMini lens examples; use the product configurator for the full offered set and current availability. FOV values are supplier specifications, while IFOV values are nominal calculations from 12 µm pitch divided by focal length. They are not guaranteed DRI ranges. Freeze the lens, interface board, frame rate and complete assembly details before production; the separate 25 Hz radiometric version requires an availability enquiry.
For the AeroMini interface shown here, use the official 16-pin USB/CVBS schematic, its pin-definition table and the AeroMini datasheet PDF. POWER_IN1 is a 5 V input. The AeroMini developer resources include serial commands and USB SDK material; verify the board, firmware and host before use. These documents do not define VisionCube wiring or software support.
5. Comparative Technical Benchmark
The following engineering comparison contrasts the standalone AeroMini 640 non-radiometric 9 mm configuration with the AI VisionCube DT Pro, which combines two visible cameras and one thermal camera. Component figures are not complete-kit specifications; undocumented items need confirmation before design freeze.
| System Parameter | CAMCUDA AeroMini 640 Imaging Core | AI VisionCube DT Pro |
|---|---|---|
| Primary Architecture | Standalone LWIR imaging core; non-radiometric configuration | Dual visible cameras + LWIR thermal camera + 6 TOPS AI processing |
| Thermal Resolution & Pitch | 640 × 512 | 12 µm | uncooled VOx | 640 × 512 | 12 µm; detector material not specified |
| Visible (EO) Channels | None included in the standalone thermal core | Dual visible: 1080p at 30 Hz | 3.9 mm wide + 12 mm telephoto |
| Thermal Frame Rate & NETD | 60 Hz default / 30 Hz option | ≤30 mK at 25 °C, F/1.0 | 50 Hz | NETD not specified on the current listing |
| Selected Optics | 9 mm LWIR | 48.7° H × 38.6° V | 9.1 mm LWIR | 45.9° H × 36.9° V; wide and telephoto visible lenses |
| Nominal IFOV (Selected Thermal Lens) | 1.333 mrad; calculated angular sampling pitch | 1.319 mrad; calculated angular sampling pitch, not a tracking-distance rating |
| Onboard AI Inference | No advertised onboard AI capability; plan external processing if required | 6 TOPS advertised processing; CPU and simultaneous track count need confirmation |
| Video & Control Interfaces | Selected USB + CVBS + MIPI board; qualify the host and output mode | Thermal camera USB documented; request the complete board output/control protocol and SDK |
| Input Voltage | Illustrated POWER_IN1 / POWER_IN2 pins: 5 V; verify the exact board | 9–16 V processing-board reference; confirm wiring |
| Power Consumption | <0.5 W typical module power at 25 °C; kit may differ | Not specified; request total and peak power for the complete kit |
| Form Factor & Mass | 21 × 21 × 28 mm and <20 g, excluding lens and flange | Board: 38 × 38 × 29 mm, 43.8 g; thermal camera: ≤23 g excluding lens/connectors; complete kit not specified |
6. Electrical, Interface, and Thermal Dissipation Integration
When you sit down to integrate heat sensor cameras into industrial enclosures, airborne 2-axis or 3-axis gimbals, or autonomous mobile robots (AMRs), you have to respect mechanical, electrical, and optical design boundaries.
1. Thermal Dissipation and Grounding Architecture
Uncooled microbolometer output can drift as detector and camera temperatures change. Nearby regulators and processors can contribute to thermal changes inside an enclosure, so evaluate image uniformity and, where applicable, radiometric stability in the intended mounting and operating conditions:
- ⚠️ Conduction Heat Paths: Follow the module manufacturer’s mounting and heat-removal guidance. Check case temperature and image stability in the final enclosure, including sustained processor load. Select thermal interfaces for the actual mechanical and thermal design; no single enclosure material or minimum gap-pad conductivity applies to every core.
- ⚠️ Clean DC Power Delivery: Use the module manufacturer’s specified supply voltage, current, and allowable ripple. Validate power integrity, grounding, and image quality under load. Filtering or regulation should follow the module requirements; a universal 30 mVpp limit or compulsory LDO architecture is not established.
2. Interface Selection: MIPI vs. USB UVC vs. CVBS
Picking your video interface locks in your hardware architecture and software stack early in the design cycle:
- ⚙️ MIPI CSI-2: A common camera link for embedded hosts. Confirm lane configuration, data rate, timing, payload format, connector, and driver support. CSI-2 can carry different image formats; the interface alone does not guarantee 14-bit raw data, radiometry, ISP processing, or sub-millisecond system latency.
- ⚙️ USB UVC (USB Video Class): Class-compliant cameras can use standard operating-system video drivers, which is useful for bench testing and workstations. Check the supported OS, bandwidth, controls, and stream formats; UVC can support color or non-color image data depending on the camera and host.
- ⚙️ CVBS (Analog Composite): An option for compatible legacy analog displays and video links. Confirm PAL/NTSC support and measure latency through the complete camera, link, and display. A standard composite video image does not itself provide calibrated per-pixel temperature data.
3. Optical Materials and Environmental Protection
Standard visible-light optical glasses such as BK7 and fused silica are not suitable transmitting elements for the 8 µm to 14 µm LWIR band. Thermal optics require materials and coatings selected for the intended infrared band:
- 📌 Germanium (Ge): Has a high refractive index (n ≈ 4.0 near 10 µm) and is widely used for LWIR optics. Image quality still depends on the complete lens design. Anti-reflection and durable coatings, including suitable DLC options, should be selected and qualified for the required transmission and exposure conditions.
- 📌 Chalcogenide Glass: An amorphous material containing chalcogen elements such as sulfur, selenium, or tellurium. Suitable grades can be precision molded for volume production. Some grades have a lower refractive-index temperature coefficient (dn/dT) than germanium, which can aid athermalization; focus stability also depends on lens geometry, expansion, and mounting. Verify the finished assembly’s operating range.
7. Deep-Dive Technical FAQ
How does an uncooled heat sensor camera measure surface temperature without physical contact?
Why do many entry-level thermal cameras use 256×192 sensors, and when is an upgrade to 640×512 necessary?
What core hardware and electrical constraints must be validated before freezing an OEM thermal module design?
What is the practical engineering difference between radiometric thermal cores and imaging-only thermal modules?
8. Engineering Consultation & Next Steps
Technical author: Daniel · Hardware Support; Sales contributors: Vivian, Lena and Sophie.
Integrating an uncooled thermal core into an industrial automation platform, inspection gimbal or unmanned aerial vehicle comes down to matching detector physics to embedded compute constraints. Use the configuration-specific documentation above, the CAMCUDA Vision Engineering Blog and a project review to confirm interfaces, optics, mechanical drawings and evaluation requirements. Request any missing DT Pro protocol, SDK or wiring information for that model.
📚 References & Further Reading
- Industry Standard: JIIA CoaXPress Certification Program
- Detector Science Reference: LYNRED detector technologies and NETD
- Related Payload Guide: Choosing 640×512 Thermal Modules for Drone Payloads
- Current Hardware References: AeroMini 640 imaging core and AI VisionCube DT Pro configuration