Drone Thermal Camera Module: 9 Proven Checks for Reliable UAV Payloads
drone thermal camera module decisions become safer when the buyer connects product parameters to the real application: drone payload, outdoor observation, OEM embedded device, or industrial inspection. This guide uses CAMCUDA product context and practical RFQ questions so the drone thermal camera module choice is easier to validate.
drone thermal camera module: quick answer for reliable module selection
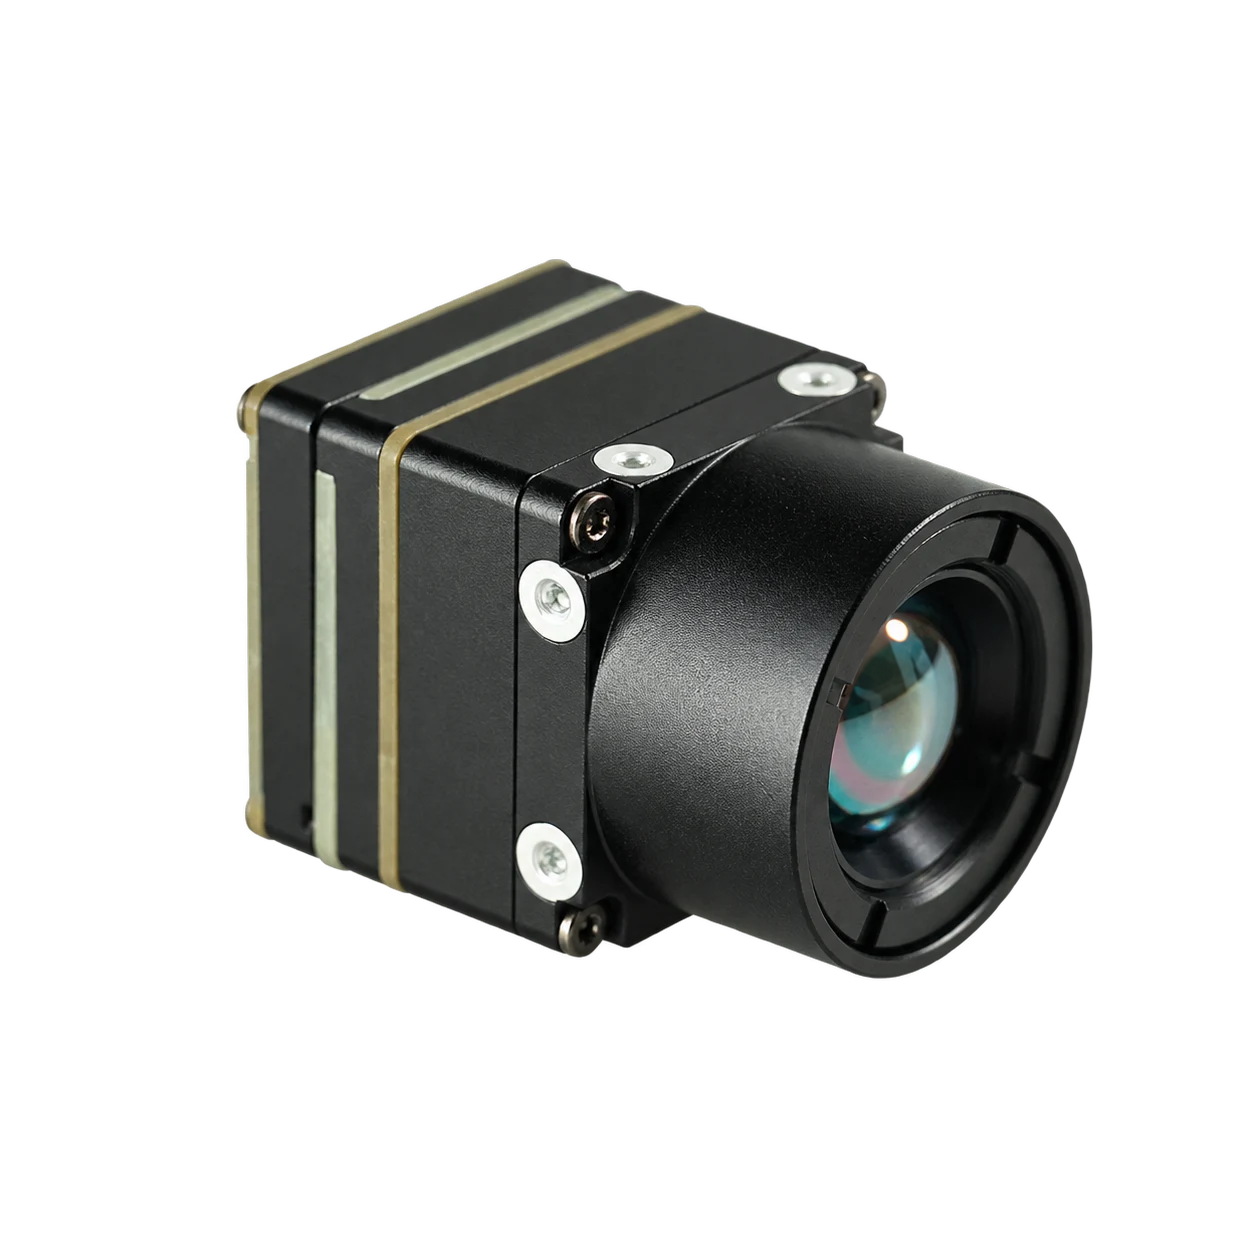
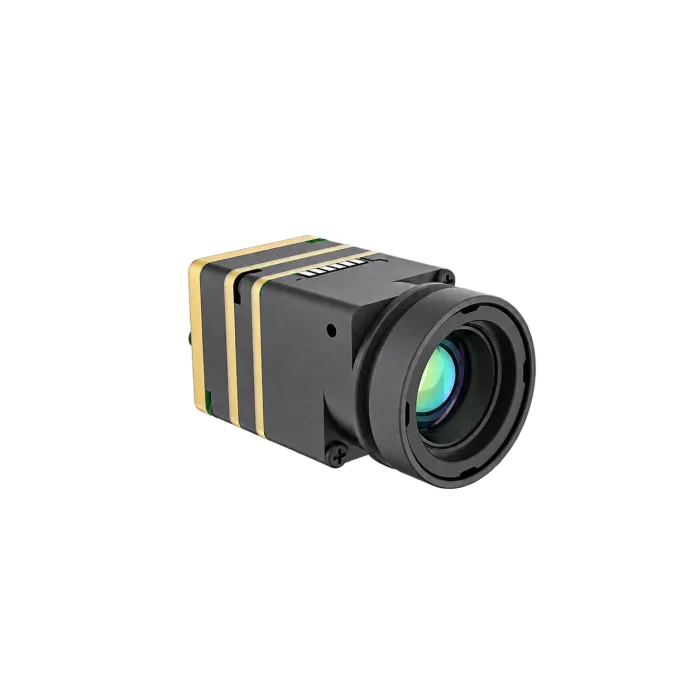
Start with CAMCUDA AeroMini 640 for a configurable drone thermal camera module, then compare SuperMini 640 when core size and mass are tighter constraints. Choose the imaging version, lens and interface board, and check the complete payload budget before ordering. Both imaging-only models show thermal patterns without calibrated temperature measurements.
drone thermal camera module payload selection chart
A drone thermal camera module should be selected by payload fit, thermal detail, power, interface, and inspection workflow.
| Drone question | Value to check | Why it matters |
|---|---|---|
| Can the payload stay light? | Complete assembly mass: core, lens, board, cable and mount | Protects flight time and stability. |
| Can video stay smooth? | AeroMini imaging: 60 Hz default / 30 Hz factory option; SuperMini imaging: 50 Hz | Useful for moving UAV scenes. |
| Is detail enough? | 640 × 512 resolution | Relevant for solar, roof, and equipment inspection. |
| Can the host integrate it? | Video and control paths for the selected interface board and host | Controls development workflow. |
Drone solar inspection case
A solar farm inspection payload needs thermal contrast, stable video, and a reporting workflow. The drone thermal camera module choice should be matched to flight height, panel size, lens/FOV, and required report detail.
If the report requires calibrated temperature readings, select a confirmed radiometric configuration. Imaging-only AeroMini 640 and SuperMini 640 do not measure temperature.
AeroMini and SuperMini values relevant to drone payloads
| Parameter | AeroMini 640 — imaging | SuperMini 640 — imaging | Selection meaning |
|---|---|---|---|
| Detector type | Uncooled VOx | Uncooled VOx | Both are LWIR integration cores; select the complete assembly. |
| Resolution | 640 × 512 | 640 × 512 | Match lens/FOV and flight height to the required target detail. |
| Imaging frame rate | 60 Hz factory default; 30 Hz factory option | 50 Hz | These are imaging-only versions. Confirm the output frame rate for the selected interface, firmware and host. |
| Pixel pitch | 12 μm | 8 μm | Use each model’s lens/FOV data; equal focal lengths do not give equal fields of view. |
| Spectral range | 8–14 μm | 8–14 μm | Confirm that the enclosure window is suitable for LWIR transmission. |
| NETD | ≤30 mK at 25°C, F/1.0 | ≤40 mK at 25°C, F1.0 | Compare the stated test conditions and validate thermal contrast in the intended scene. |
| Power input | 5 V or 12 V, board-dependent; illustrated POWER_IN1 / POWER_IN2 pins are 5 V inputs | MAIN_POWER: 3.8–5.2 V; separate regulated 3.3 V and 1.8 V rails | Do not connect AeroMini’s illustrated 5 V pins to 12 V. Confirm the chosen board, rail tolerances, noise limits and power-on timing. |
| Typical power at 25°C | <0.5 W module consumption; complete-kit consumption may differ | ≤0.5 W core consumption, excluding expansion board | Add interface hardware, host processing and video transmission to the system power budget. |
| Video interface | USB + CVBS + MIPI or Type-C + CVBS kits; output depends on board and firmware | 8-bit LVCMOS / BT656 and 2-lane MIPI; optional USB expansion board | Confirm host compatibility. SuperMini BT656 and MIPI cannot operate simultaneously; its CVBS pin requires an external video-buffer IC. |
| Control interface | UART, RS232 or RS422, depending on interface board | UART with 1.8 V logic | Confirm the command protocol, logic levels, connector and cable for the ordered configuration. |
| Published weight | <20 g, excluding lens and flange | <3.5 g, excluding lens, flange and user expansion board | These measurement scopes differ and are not complete payload weights. Confirm all supplied boards, cables and mounting hardware. |
| Published dimensions | 21 × 21 × 28 mm, excluding lens and flange | 13 × 13 × 13.4 mm, excluding lens, flange and user expansion board | Use the configured assembly drawing for the gimbal, enclosure and cable-clearance check. |
| Operating temperature | −40°C to +80°C | −40°C to +70°C for imaging | Thermographic operating and accuracy conditions are separate; validate the complete enclosure. |
| Humidity | 5–95%, non-condensing | 5–95%, non-condensing | Enclosure design still matters for condensation control. |
| Vibration / shock | Request qualification limits for the selected assembly | Confirm the applicable core and assembled-payload test requirements | Validate vibration and shock limits for the configured payload and mount before flight. |
Temperature-measurement versions: AeroMini 640 radiometric is a separate 25 Hz version, documented with 9, 13 or 18 mm lenses and a −20°C to +550°C measurement range. It is currently out of stock and available for supply enquiries only; interface, accuracy and data format require confirmation. SuperMini 640T is the separate 30 Hz thermographic model, with −20°C to +150°C and 100°C to +650°C ranges. Its typical accuracy is ±2°C or ±2% of reading at −20°C to +60°C ambient. These specifications do not apply to the imaging-only models above.
Use the current AeroMini 640 specifications and board connections and SuperMini 640 / 640T specifications and manual for configuration review. Confirm the lens, complete assembly mass, supplied items and software package before requesting a sample. AeroMini’s illustrated 16-pin and 26-pin connections are not a substitute for the matched Type-C board wiring guide.
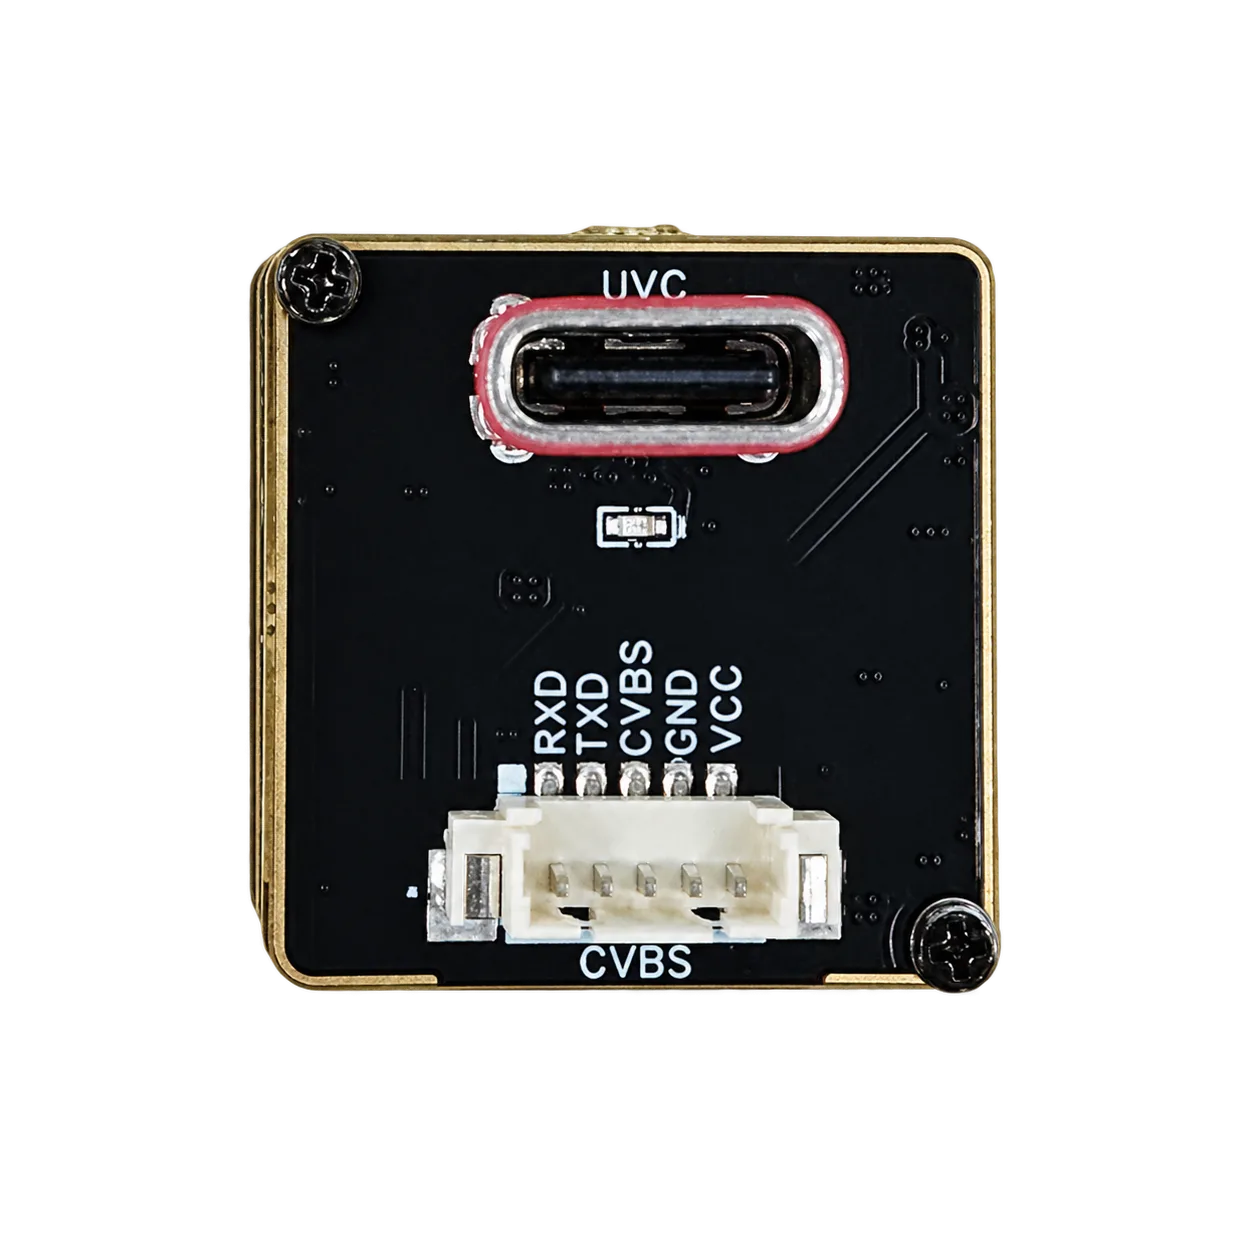
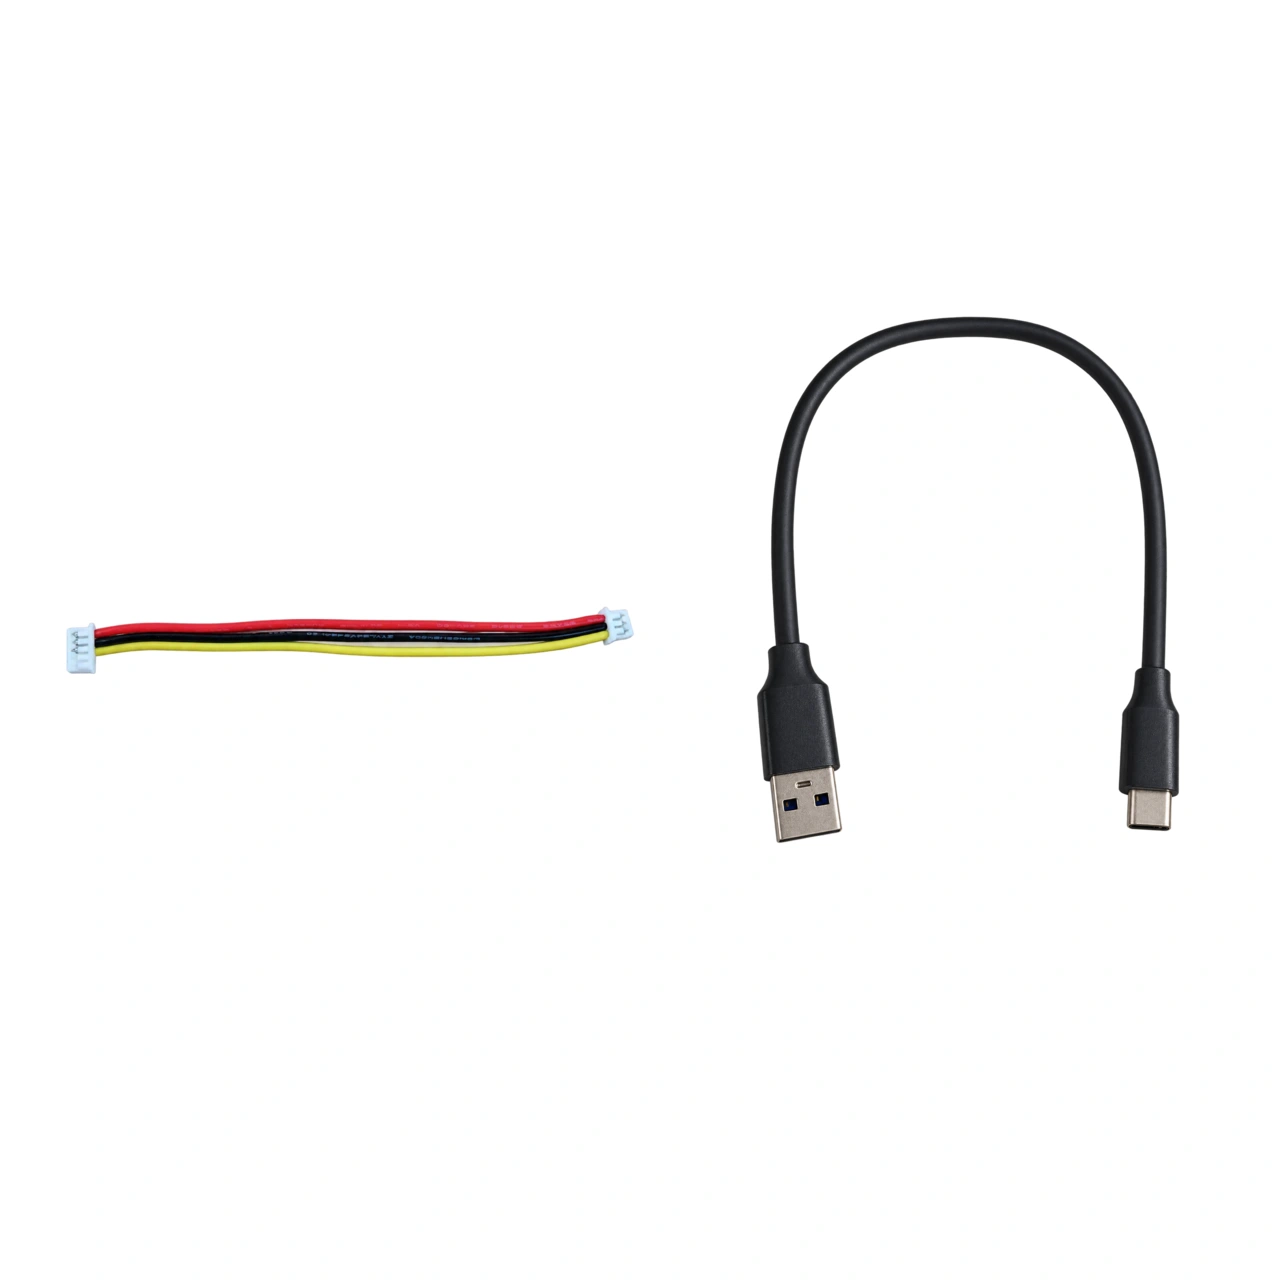
Obtain the wiring guide matched to this Type-C tailboard before connecting power or serial signals. The 16-pin and 26-pin diagrams in the complete AeroMini datasheet describe a different illustrated board. SuperMini has its own 30-pin core interface in the complete manual, PDF pages 6–7.
For a MIPI host path, the MIPI Alliance CSI-2 overview explains camera-to-processor image transport. Then check the selected module’s lane configuration, data format, firmware and host receiver support; the general interface reference does not establish product-specific compatibility.
Common drone payload mistakes
- Assuming every thermal drone needs the same resolution.
- Ignoring payload weight after adding mount, lens, and cable.
- Not defining inspection altitude and target size.
- Expecting module output to equal a finished drone camera.
Drone thermal camera module RFQ checklist
- Aircraft type and payload limit.
- Flight height and target size.
- Lens/FOV requirement.
- Host video path and control interface.
- Expected quantity and destination market.
For an initial SuperMini core-space check, see the bare-core mechanical drawing, PDF page 13. The lens, expansion board, connectors and cable bends need separate assembly-level clearance; use the drawing for the ordered configuration.
Build a safer drone payload shortlist
Read Drone Thermal Camera Application, review AeroMini 640 configurations and SuperMini 640 / 640T, or contact CAMCUDA RFQ.
FAQ from drone thermal buyers
Is a drone thermal camera module a finished payload?
No. It is usually a module/core path that still needs lens, mount, enclosure, electronics, and software.
Is 640 × 512 useful for solar inspection?
It can be, especially when more scene detail is required, but lens/FOV and flight plan decide final usefulness.
Why do pilots discuss thermal inspection pricing?
Because deliverables, site size, reporting, weather, and standards affect the job beyond camera hardware.
Does low weight matter?
Yes. Every gram can affect flight time, stability, and mount design.
Is USB practical for drones?
It can be practical for evaluation, but host hardware and software must be confirmed.
What should be in the RFQ?
Aircraft, payload, distance, lens/FOV, interface, quantity, and market.
Can one module serve multiple drone missions?
Sometimes, but lens and reporting requirements can change by mission.
Should I buy by price first?
No. Start with mission and integration fit, then compare price.
drone thermal camera module validation workflow before purchase
A practical drone thermal camera module validation workflow should start with a written requirement sheet. The sheet should name the application, target distance, lens/FOV expectation, host processor, interface path, power rail, mechanical envelope, operating environment, quantity range, and destination market. This simple document makes the supplier conversation more useful than a generic request for price.
For engineering teams, the second step is a bench test plan. Confirm whether the drone thermal camera module can produce usable video on the intended host, whether the control path is documented, whether the module can be powered safely, and whether the image settings are enough for the target scene. For procurement teams, the same test plan becomes a checklist for comparing samples and supplier responses.
The third step is a field or application simulation. A drone payload should be checked against weight, vibration, flight height, and reporting workflow. An outdoor system should be checked against enclosure, condensation risk, lens window, mounting position, and day/night operation. An OEM embedded system should be checked against PCB layout, cable exit, software integration, and future production repeatability.
Example RFQ language for CAMCUDA
Instead of writing only “please quote a drone thermal camera module,” use a more complete request: “We are building a thermal imaging product for [application]. The host platform is [processor/system]. We need [interface] output, [lens/FOV] target, [quantity] units, and the destination market is [region]. Please recommend a module path, drawing/document package, sample availability, and integration risks.”
This RFQ style improves technical matching and helps CAMCUDA respond with a useful product path. It also protects the buyer from comparing incompatible modules just because they share a similar resolution or product photo.
How to compare suppliers for drone thermal camera module
When comparing suppliers, avoid a spreadsheet that only lists price and resolution. A stronger drone thermal camera module comparison should include whether the supplier can provide product detail pages, drawings, interface notes, realistic lead-time discussion, media assets, and application guidance. A supplier that can explain integration risk is usually easier to work with than one that only sends a short quote.
For CAMCUDA buyers in Europe and North America, documentation and communication also matter. Ask whether the supplier can confirm the product model, clarify the interface, explain what is included in the module scope, and identify which requirements need engineering review. If the answer is vague, the project may still be possible, but the buyer should treat the quotation as incomplete.
Acceptance test checklist after samples arrive
- Confirm the shipped model matches the quoted drone thermal camera module path.
- Check basic power-up behavior with the intended host or evaluation platform.
- Verify video output and control communication before mechanical integration.
- Compare image output under at least two realistic scenes.
- Review mechanical fit with cable, mount, enclosure, and lens/window constraints included.
- Record questions for the supplier before moving to production quantity.
This acceptance step is especially important for thermal imaging projects because many issues do not appear in a product photo. The drone thermal camera module may look correct but still require interface adjustment, lens matching, or enclosure changes. Treat the first sample as an engineering validation tool rather than a final production approval.