ir camera module: 7 Essential Checks for Reliable Drone OEM Integration
Drone OEM integration guide
ir camera module: 7 Essential Checks for Reliable Drone OEM Integration
An ir camera module is not just a resolution line in a datasheet. For a drone payload team, it is a chain of decisions: detector, video output, command interface, power budget, mechanical envelope, lens/FOV, compliance documents, and the way the buyer will validate the first prototype.
Quick answer: choose the ir camera module around the host system, not around one headline spec
If your project is a compact UAV payload, start with the host processor and video path. USB is practical for evaluation and embedded computers, RS-422 is useful for robust command/control wiring, and CVBS analog output can matter when the drone system must feed a legacy low-latency transmitter or analog monitor. CAMCUDA’s featured AeroMini 640 provides a 640 x 512 uncooled VOx LWIR platform with a 60 Hz non-radiometric default or a 30 Hz factory option. Choose the USB + CVBS + MIPI or Type-C + CVBS board for the host; control interfaces and output modes must be confirmed for that board. SuperMini 640 / 640T is a separate bare-core comparison for tighter size and weight limits.
Many buyers search for an ir camera module after a prototype has already hit a wall. The detector looked suitable, but the embedded computer could not keep a stable stream. The module was small enough, but the lens stack pushed the gimbal over its balance target. The thermal image looked good on a bench, but the field team still needed analog video for an existing downlink. Those problems are not exotic; they are the normal difference between a component purchase and a working drone payload.
This guide is written for engineering teams and procurement teams in Europe and North America who need a compact LWIR thermal module for drones, outdoor observation, industrial inspection, or OEM devices. It uses CAMCUDA’s featured AeroMini 640 as the primary product reference and SuperMini 640 / 640T as the bare-core comparison, and it separates confirmed product facts from project-specific items that must be checked during RFQ.
ir camera module selection map for drone OEM teams
A useful selection map starts with the job the drone must do. Search and rescue, night patrol, perimeter monitoring, roof inspection, and industrial equipment checks do not place the same demands on lens, frame rate, output, or documentation. The table below turns common buying questions into practical checks before a purchase order is placed.
| Decision area | What to check first | Why it matters on a drone | CAMCUDA note |
|---|---|---|---|
| Resolution | Whether 640 x 512 is enough for detection and operator interpretation | More pixels can help with scene understanding, but payload cost, optics, and processing load still matter | AeroMini 640 and SuperMini 640 / 640T use 640 x 512 detectors |
| Detector type | Uncooled LWIR VOx platform | Uncooled LWIR avoids cryogenic cooling and is practical for compact UAV payloads | Vanadium oxide uncooled infrared focal plane detector |
| Interface | USB, RS-422, and whether CVBS analog output is needed on the project | The wrong output path can force redesign of the flight computer or video transmitter | AeroMini offers USB + CVBS + MIPI and Type-C + CVBS boards; the illustrated 16-pin board labels RS232, not RS-422. Confirm the exact control path |
| Frame rate | Thermal stream requirement for moving platform | Low frame rate can make fast pans harder to interpret | AeroMini: 60 / 30 Hz non-radiometric, 25 Hz radiometric enquiry; SuperMini: 640 imaging 50 Hz or 640T thermographic 30 Hz |
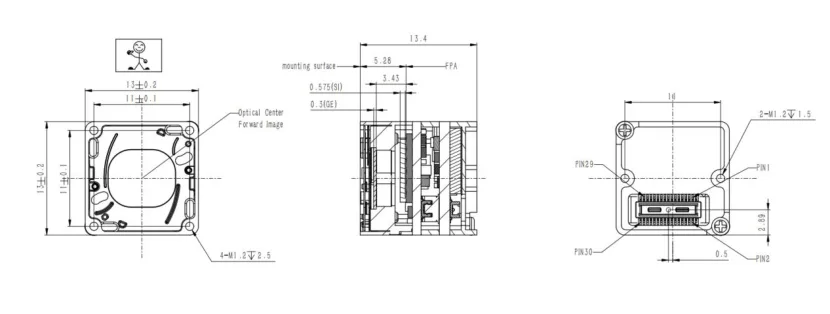
| Mechanical envelope | Module body, lens space, connector exit, and gimbal balance | A few millimeters can change the entire payload layout | AeroMini: 21 x 21 x 28 mm without lens/flange; SuperMini: 13 x 13 x 13.4 mm bare core, excluding optics and boards |
| Procurement documents | NDAA statement, compliance context, and application notes | North America buyers often need written documentation before approval | Request NDAA-related documents for the exact configuration and have procurement review their scope and suitability |
Featured ir camera module data: AeroMini 640
The table below uses product-page data for CAMCUDA’s featured AeroMini 640. These values should be treated as the baseline for content, RFQ, and technical discussion. If a project needs a different lens, housing, connector route, video output, or compliance pack, confirm that as a configuration request rather than assuming the same module includes every option by default.
| Product | AeroMini 640 Uncooled LWIR Thermal Camera Module |
|---|---|
| Detector type | Vanadium oxide uncooled infrared focal plane detector |
| Resolution | 640 x 512 |
| Pixel pitch | 12 um |
| Spectral range | 8-14 um |
| NETD | ≤30 mK @ 25°C, F#1.0 |
| Frame rate by version | Non-radiometric: 60 Hz default / 30 Hz factory option; radiometric: 25 Hz, availability enquiry only |
| Supply voltage | POWER_IN1 / POWER_IN2 on the illustrated 16/26-pin board are 5 V inputs; do not apply 12 V. Confirm the matched board guide |
| Typical power consumption | <0.5 W at 25°C for the module; complete-kit consumption may differ |
| Video interface package | USB + CVBS + MIPI or Type-C + CVBS; distinct tailboards, with output mode and host compatibility to be confirmed |
| Communication interface | UART / RS232 / RS422 availability is board-dependent; the illustrated 16-pin schematic labels RS232 |
| Weight | <20 g, excluding lens and flange |
| Dimensions | 21 mm x 21 mm x 28 mm, excluding lens and flange |
| Operating temperature | -40°C to +80°C |
| Storage temperature | -50°C to +85°C |
| Matched-configuration quotation | Confirm camera version, frame rate, lens, interface board, supplied items, quantity and delivery terms in the quotation |


Drone case: a patrol payload that needs thermal video and an analog fallback
Imagine a small UAV team building a night patrol payload for industrial perimeter checks. Their first goal is simple: show a thermal scene to an operator and record enough imagery for review. The second goal is less obvious: the drone platform already has an analog video transmitter in one version, while a newer version uses an embedded computer with USB capture.
In this situation, choosing an ir camera module only by resolution would be a mistake. The team should map two paths. The engineering prototype can use USB video because it is fast to validate on a development computer. The production version may still need a low-latency analog path if the aircraft, display, or recorder is built around CVBS. AeroMini offers CVBS on its named interface packages, but the buyer should confirm the board, firmware, output standard and receiver during RFQ together with lens/FOV, cable exit, and expected operating environment.
The practical workflow is to test the thermal module on a bench, then mount it in a rough payload shell, then fly a short validation route at night. During that test, the team should watch for thermal contrast, stream stability, gimbal vibration, heat soak, connector movement, and operator reaction. The best module on paper is still only useful if the pilot can interpret the scene quickly.
7 essential checks before buying an ir camera module
1. Confirm the video path before choosing the enclosure
USB video, MIPI, DVP, and CVBS lead to different host designs. USB is convenient for development and many embedded computers. MIPI and DVP are deeper embedded paths. CVBS analog output remains useful for some drone downlinks, older displays, FPV-style monitoring, or retrofit projects. AeroMini offers distinct USB + CVBS + MIPI and Type-C + CVBS tailboards. Do not apply the first board’s 16/26-pin definitions to Type-C or assume that every output can deliver the selected frame rate simultaneously. SuperMini’s 30-pin bare-core interface is different: BT656 and MIPI cannot operate simultaneously, CVBS requires an external video-buffer IC, and the 640T uses CDS3 for image and temperature data.
2. Separate command/control from image output
A team may receive video through one path and send commands through another. AeroMini lists UART, RS232 and RS422 at family level, with availability depending on the interface board. The illustrated 16-pin board labels RS232; it does not establish an RS-422 connection. SuperMini uses 1.8 V UART, with TX/RX named from the core. RS-422 is often attractive when wiring distance, noise tolerance, or platform architecture makes a differential command link preferable.
3. Check SWaP as a system number
SWaP means size, weight, and power, but it should include the lens, cable, mounting screws, thermal path, and enclosure. AeroMini is listed at less than 20 g and 21 x 21 x 28 mm without lens and flange, with typical module power below 0.5 W at 25°C. SuperMini is less than 3.5 g and 13 x 13 x 13.4 mm as a bare core, excluding optics and boards; its typical core power is ≤0.5 W at 25°C, excluding the expansion board. A flight-ready payload will weigh and consume more after the other components are added.
Power integration also differs. AeroMini’s illustrated POWER_IN1 / POWER_IN2 inputs require 5 V, not 12 V. SuperMini’s bare core needs MAIN_POWER at 3.8–5.2 V (typical 5 V), +3.3 V at 3.28–3.32 V, and +1.8 V at 1.78–1.82 V. Follow the SuperMini manual’s rail-noise limits and power-on sequence; a complete module kit is not defined by bare-core power alone.
4. Match lens and FOV to the mission
A wide FOV helps situational awareness at close distance. A narrower lens helps longer inspection distance but can make piloting and search workflows harder. For drone payloads, lens selection should be tied to flight altitude, expected target size, and display resolution.
5. Read NETD together with image processing
NETD matters because low thermal contrast scenes can be difficult to interpret. AeroMini is listed at ≤30 mK and SuperMini at ≤40 mK, both at 25°C, F#1.0. SuperMini uses an 8 um pixel pitch; AeroMini uses 12 um. Evaluate the delivered image-processing settings and low-contrast scenes on the intended host rather than choosing by NETD alone.
6. Ask for procurement documents early
For North America projects, procurement may ask for more than a quotation. If the project touches security monitoring, industrial infrastructure, or government-adjacent work, ask early whether an NDAA statement is required. Request NDAA-related documents for the exact model and configuration, then have procurement review their scope and suitability. Document availability and project eligibility must not be assumed.
7. Validate with a real mounting and thermal scene
Do not stop at a desktop preview. A useful ir camera module test includes a mounted module, representative power supply, actual cable path, target flight altitude or standoff distance, and the display/recording chain the buyer intends to use.
Use the AeroMini datasheet for the illustrated 16-pin USB/CVBS and 26-pin MIPI/DVP references, and the AeroMini Linux drivers, examples and SDK FAQ for its linked developer resources. Match the board, firmware, host, output format and frame rate before the sample test. For SuperMini, use its 640 / 640T product manual; AeroMini resources do not establish SuperMini compatibility.
Common mistakes that make good modules look bad
- Buying by resolution alone. A 640 x 512 detector can still fail the project if the output interface, lens, or mounting is wrong.
- Forgetting analog video requirements. Some teams discover late that a legacy transmitter or monitor expects CVBS. Ask before layout freeze.
- Ignoring connector bend radius. A small camera core can still need careful cable routing inside a gimbal.
- Skipping compliance documents. North America buyers should request NDAA-related documentation early and have procurement review the exact configuration.
- Testing only on a warm bench. Outdoor drones see temperature swing, airflow, vibration, and quick scene changes.
RFQ checklist for a practical ir camera module quote
A short RFQ often produces a vague answer. A better RFQ gives the supplier enough context to recommend the correct configuration and documentation. Before contacting CAMCUDA, prepare the following:
| RFQ item | Example detail to send |
|---|---|
| Application | Drone night patrol, roof inspection, search and rescue, industrial monitoring, or embedded OEM vision |
| Target resolution | 640 x 512, or explain why lower/higher resolution is being considered |
| Video output | USB for embedded computer, CVBS analog output if required, or other host interface expectation |
| Control interface | UART logic level, RS232, RS-422, USB serial, or other host-side protocol requirement; confirm the selected board supports it |
| Lens/FOV | Flight altitude, expected target size, inspection distance, or desired FOV |
| Mechanical limits | Max module/lens envelope, gimbal limits, cable exit direction, mounting constraints |
| Market and compliance | Europe/North America destination, NDAA statement requirement, project documentation expectations |
For buyers who want to compare product paths, start with CAMCUDA products, review drone thermal camera applications, and send requirements through CAMCUDA Contact / RFQ.
Need help matching the module to a real payload?
Start with the AeroMini 640 product page, compare SuperMini 640 / 640T if a bare-core design fits your integration resources, then send your application, interface path, lens/FOV target, quantity, and destination market. Ask CAMCUDA to match the board, control link and video chain before a configuration-specific quotation.
Useful external references for engineers
For interface context, review the USB Video Class documentation and MIPI CSI-2 specification overview. For procurement language around covered telecommunications and video surveillance services or equipment, review FAR 52.204-25. These links do not replace project-specific legal or compliance review, but they help engineering and procurement teams ask better questions.
FAQ from buyer questions
Is an ir camera module the same as a complete thermal camera?
No. A module or core is usually the imaging component inside a complete device. A finished camera may also include lens, enclosure, display, recording, battery, gimbal, software, and certification package.
Does AeroMini 640 support CVBS analog video?
CVBS is offered on the AeroMini USB + CVBS + MIPI and Type-C + CVBS interface packages. Confirm the ordered board, firmware, output standard and receiver during RFQ. The 16/26-pin diagrams apply to the illustrated USB + CVBS + MIPI board, not Type-C. SuperMini is a separate bare-core design whose CVBS signal requires an external video-buffer IC.
Why do drone teams still ask for CVBS?
Some drone systems use legacy analog transmitters, FPV-style video chains, or simple field monitors. CVBS can be useful when low-latency analog viewing is more important than a digital embedded pipeline.
Is 640 x 512 enough for drone inspection?
For many compact UAV payloads, 640 x 512 is a practical balance of detail, size, cost, and processing load. The final answer depends on altitude, target size, lens/FOV, operator display, and the inspection task.
What specs should I send before asking for a quote?
Send application, destination market, target resolution, required video output, control interface, lens/FOV target, payload size limit, expected quantity, and whether NDAA statement or other procurement documents are required.
Can CAMCUDA provide an NDAA statement?
Ask CAMCUDA which NDAA-related documents are available for the exact model and configuration. Buyers should mention this early when the project involves North America procurement, security monitoring, industrial monitoring, or government-adjacent requirements, and have procurement review the documents. Availability and project eligibility are not guaranteed by this article.
What is the biggest mistake when integrating a small thermal module into a drone?
The common mistake is freezing the mechanical layout before confirming lens, interface, cable direction, power, heat path, and video chain. A small module can still create redesign work if those details are late.
Should I choose USB, MIPI, DVP, or CVBS?
Choose by host system. USB is practical for evaluation and embedded computers. MIPI and DVP fit deeper embedded architectures. CVBS is useful for applicable analog video projects. Confirm the exact configuration before purchase.
Can the same module be used for handheld devices and drones?
Sometimes, but the surrounding design changes. Drones emphasize payload weight, vibration, gimbal balance, and video transmission. Handheld devices may emphasize battery, display, enclosure, buttons, and operator ergonomics.